Mendwicket
Verified
Verified by its owner.
- October 27, 2026
Robotics motion planning, control, and safe autonomy portfolio
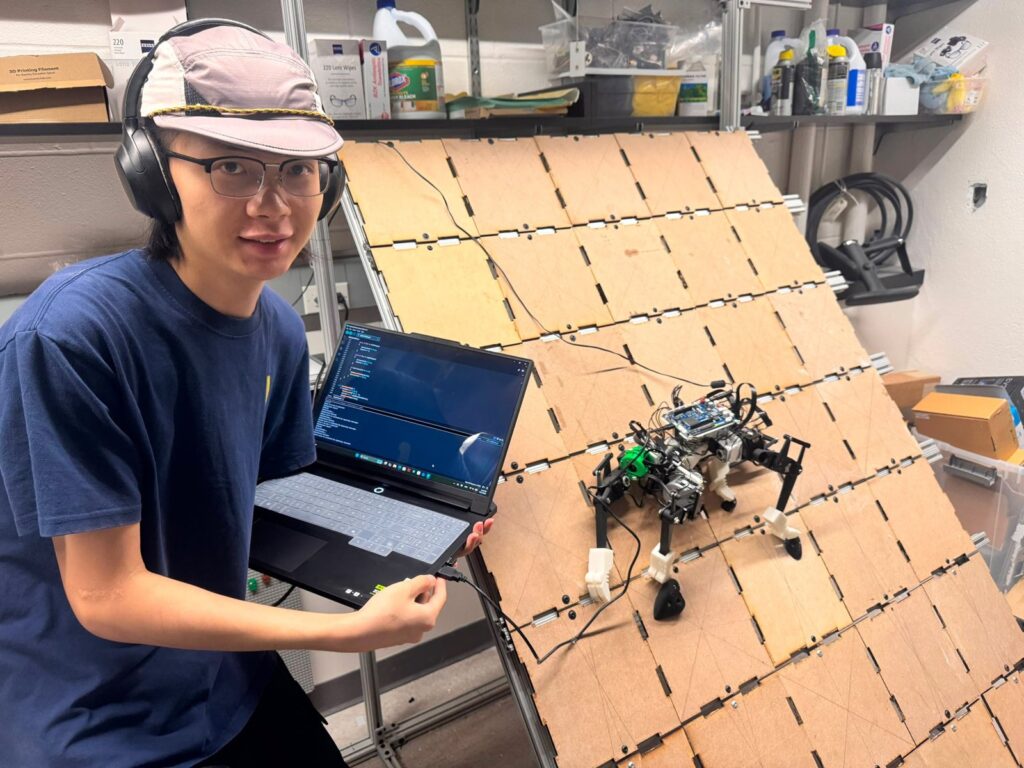
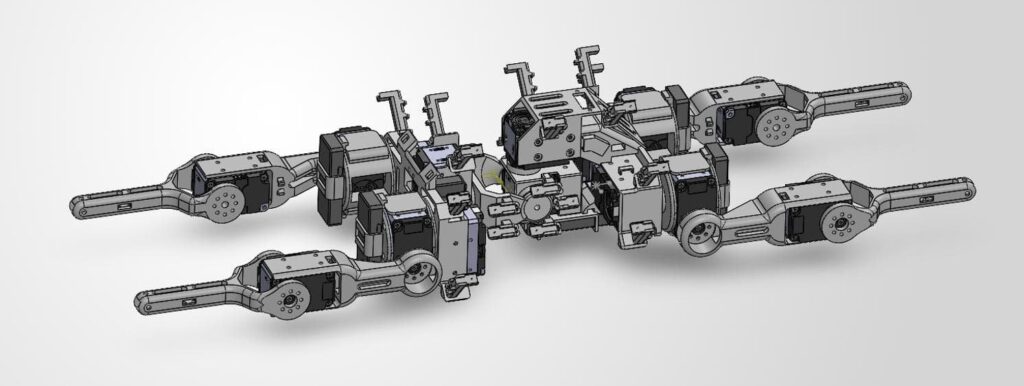
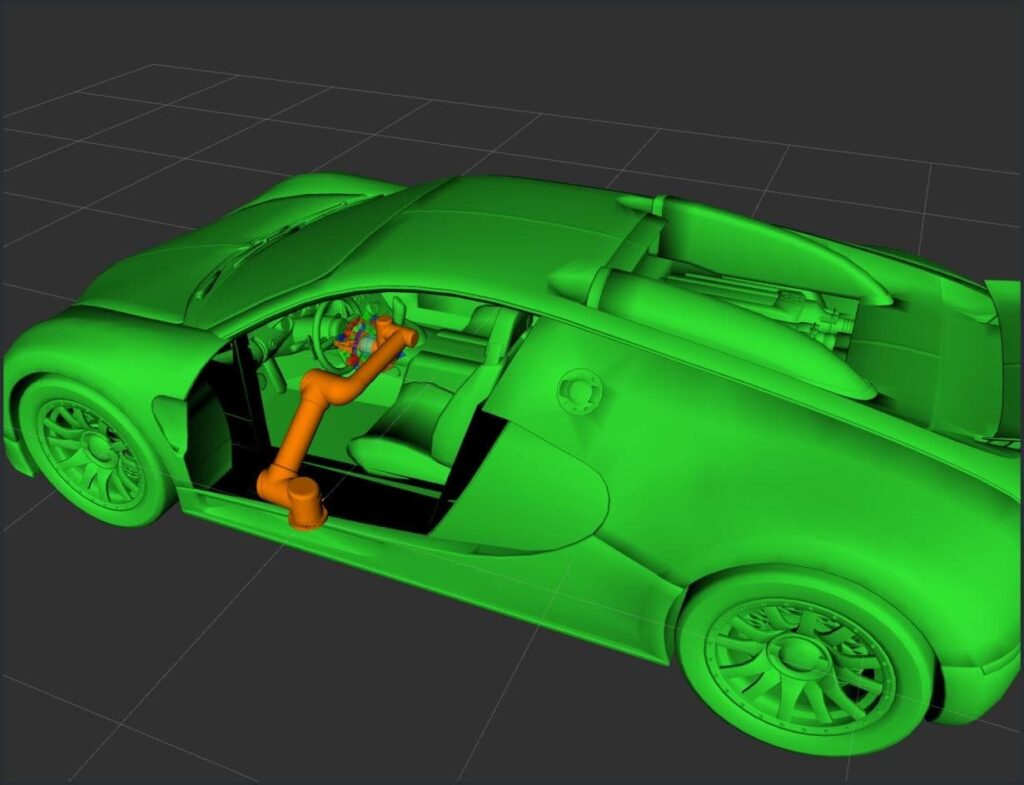
This is the personal portfolio site of Jiarun Dong, a master's student in Mechanical Engineering at Johns Hopkins University, focused on robot locomotion planning, optimal control, and safe autonomous systems. The site presents a set of research and engineering projects, including a 15-DOF active-spine quadruped robot for climbing steep terrain, a ROS 2-based NMPC-CBF safe motion controller for differential-drive robots, and a bidirectional tree motion planner combining EST heuristics with RRT-Connect for a 6-DOF manipulator. Each project outlines the algorithm design, implementation details, and simulation testing. The site is currently seeking robotics algorithm roles for the 2027 graduating class.
Yes — this listing was added because the business recently launched a new website.
Yes — use the contact details on this page, or verify this listing if you're the owner.